Hardware

Robot platforms

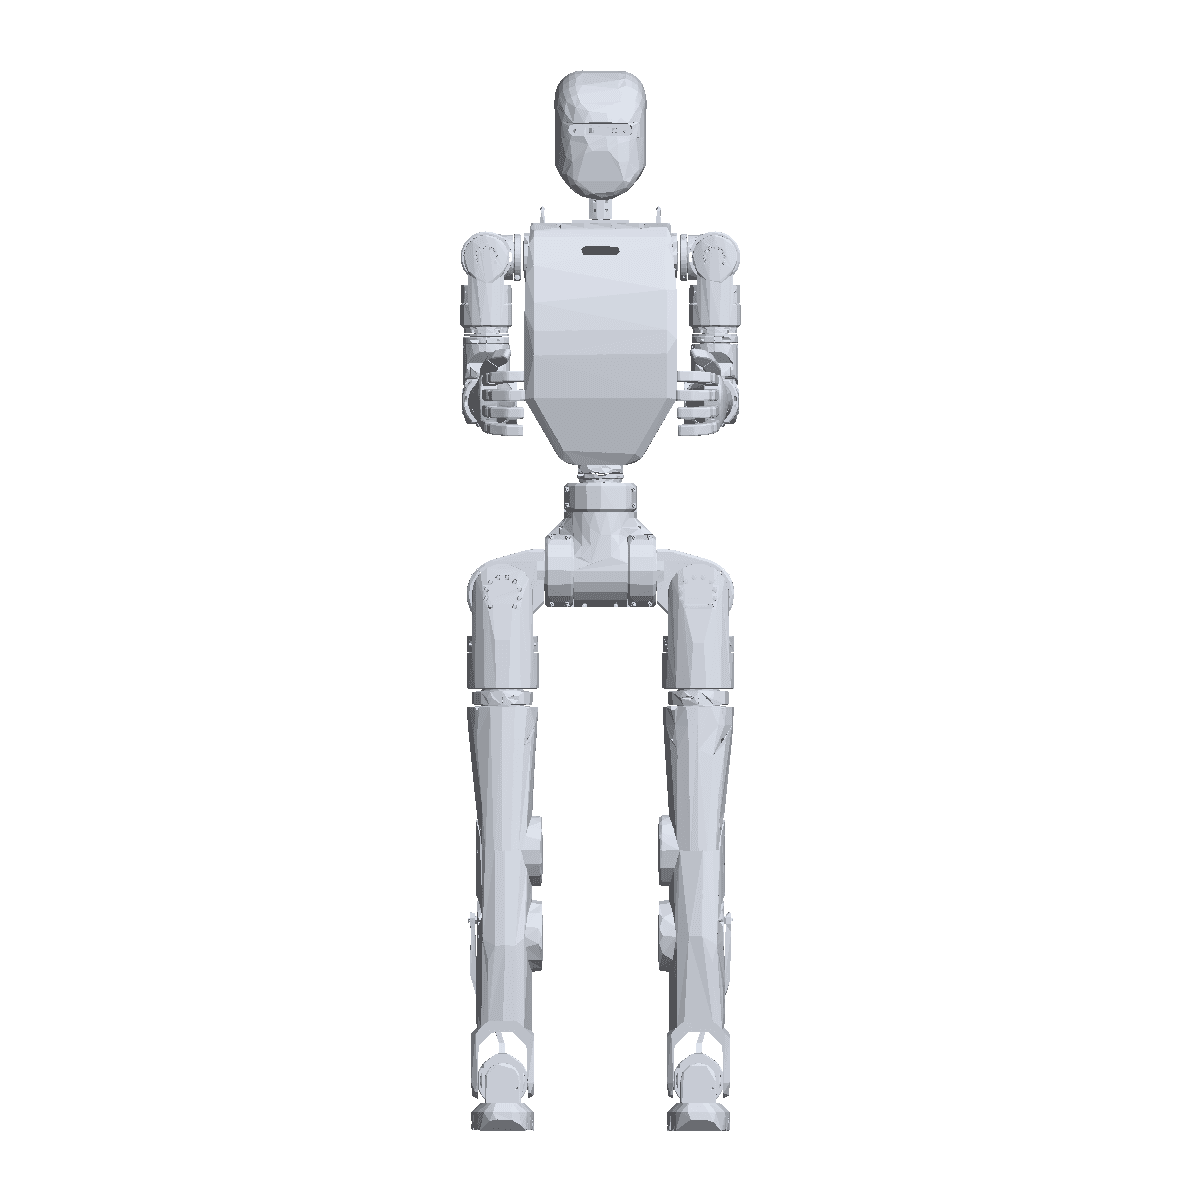
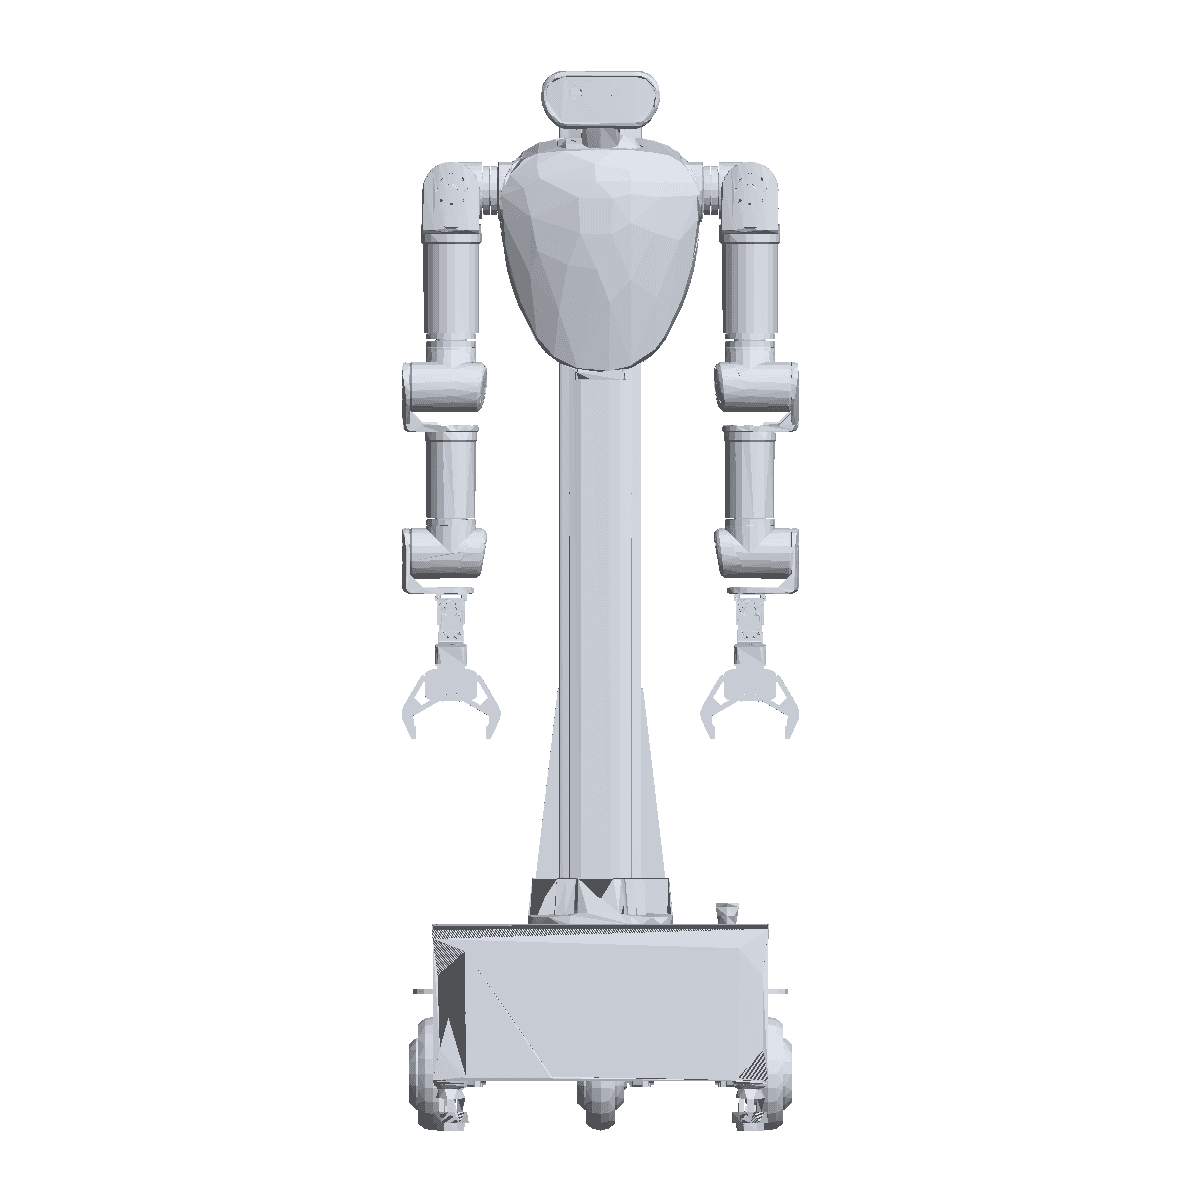
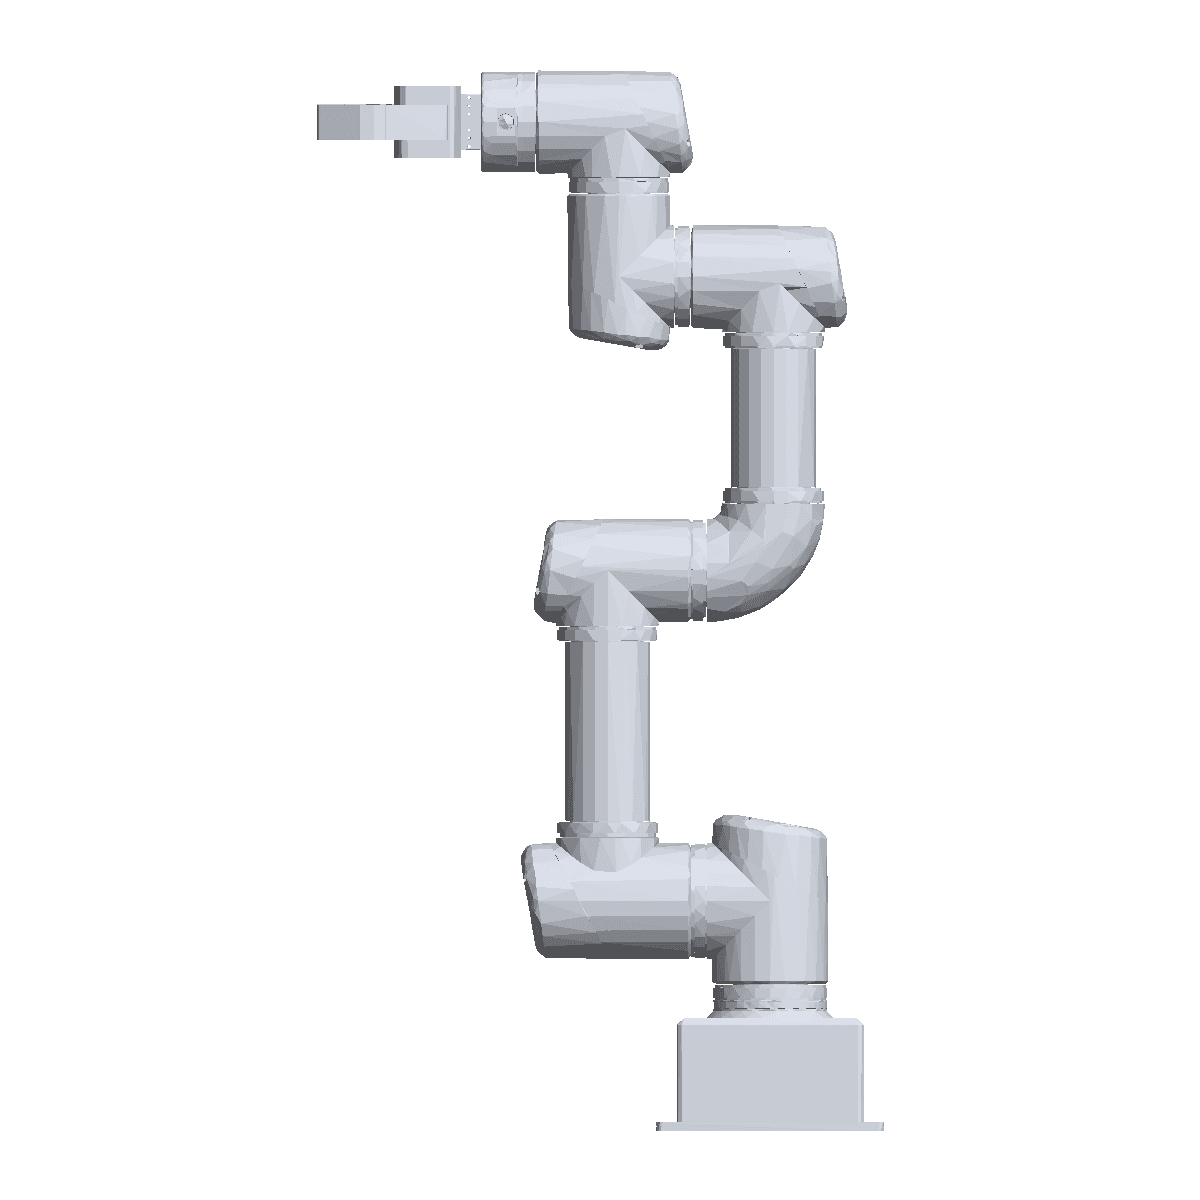
The hardware we build on. The 3D models below are rendered from the same URDF files the robots run on, and every platform listed is bookable by members unless its entry says otherwise.

AI Worker

Models are rendered from the URDF of each platform. Drag-free: move the pointer to look around.

Specifications

AI Worker

AI Worker

ROBOTIS FFW-SG2 · bimanual mobile manipulator

A bimanual mobile manipulator, and the platform our RoboCup@Home entry is built on. The swerve-drive base moves omnidirectionally, which is what lets it work in the tight spaces a furnished arena leaves between furniture.

It is the resource three activities compete for — the research track, the competition team and public demonstrations — so the research track's schedule is fixed first and everything else is planned around it.

Model
ROBOTIS AI Worker FFW-SG2
Degrees of freedom
25 total, 7 per arm
Payload
3.0 kg per arm nominal, 5.0 kg peak (6.0 / 10.0 kg dual)
Reach
641 mm to wrist, plus hand
Mobile base
Swerve drive, omnidirectional
Sensing
3 × RGB-D (ZED Mini head, 2 × RealSense D405 in the hands), 2 × LakiBeam 1 LiDAR, IMU
Onboard compute
NVIDIA Jetson AGX Orin 32 GB
Battery
25 V, 80 Ah (2,040 Wh)
Size and weight
604 × 602 × 1,623 mm, 90 kg
Units in the lab
1
Access
Members, after platform-specific safety training
Manufacturer
OMY

OMY

Robot arms · manipulation policy experiments

Two robot arms used for manipulation policy experiments and data collection. Run as a leader–follower pair, they collect teleoperation data directly.

Degrees of freedom
6
Payload
3 kg
Reach
580 mm
Repeatability
±0.05 mm
End effector
RH-P12-RN gripper with Intel RealSense D405
Units in the lab
2, run as a leader–follower pair
Access
Members, after platform-specific safety training
Manufacturer
LeRobot SO-ARM 101

LeRobot SO-ARM 101

Teaching platform · imitation learning

Two small robot arms used in the education track. A full cycle — collecting demonstrations, training a policy, evaluating it — runs short enough on these that a member new to robot learning can complete one in a session.

Degrees of freedom
6 per arm
Actuators
Feetech STS3215 bus servos with magnetic absolute encoders
Configuration
Leader and follower arms
Units in the lab
2
Access
Members; reserved for group practicals on Thursday evenings
Manufacturer

Dexterous hands

Tesollo · ROBOTIS · LEAP

Three multi-fingered hands used for grasping and in-hand manipulation research. They are booked separately from the arms, so a study can pair any hand with any platform. New policies are checked in simulation for range of motion before they run on the Tesollo hand, whose finger links are thin enough to be damaged by excessive torque or collision.

Manufacturer pages: Tesollo Delto Gripper 3F, ROBOTIS RH-P12-RN, LEAP Hand.

Tesollo Delto Gripper 3F
12 DOF (4 per finger), 1,044 g
ROBOTIS RH-P12-RN
Adaptive 2-finger, 0–106 mm stroke, 5 kg payload, 170 N
LEAP Hand
16 DOF, open-source, Dynamixel-driven
Units in the lab
1 of each
Primary use
Dexterous grasping, in-hand manipulation, hand hardware experiments

Sensors and data capture

Cameras · MANUS data glove

Seven cameras for robot vision and dataset capture, and a data glove that tracks finger joints so a person's hand motion can drive any of the robot hands directly. Camera placement and lighting are kept identical between sessions — a manipulation dataset only holds together if they are — and the layout is recorded whenever it changes.

Cameras
7
Data glove
MANUS, 1 unit
Primary use
Robot vision, teleoperation, manipulation dataset capture

Compute

NVIDIA RTX PRO 6000 workstations

Three GPU workstations for simulation, policy training and vision model experiments. Long training runs are moved to nights and weekends so they do not collide with daytime experiments on the robots.

Workstations
3
GPU
NVIDIA RTX PRO 6000 (Blackwell)
GPU memory
96 GB GDDR7 ECC each
Cores
24,064 CUDA cores, 752 fifth-generation Tensor Cores
Primary use
Simulation, policy training, vision model experiments
Manufacturer
AI Sapiens

AI Sapiens

Humanoid · previously operated

A humanoid platform SHAPE operated during its first year. It is no longer in the lab, and it is listed here because the experience of running it is part of what the team knows.

Actuators
23 Dynamixel-Q quasi-direct-drive actuators
Status
Previously operated; not currently in the lab
Primary use
Whole-body control and locomotion experiments
Manufacturer